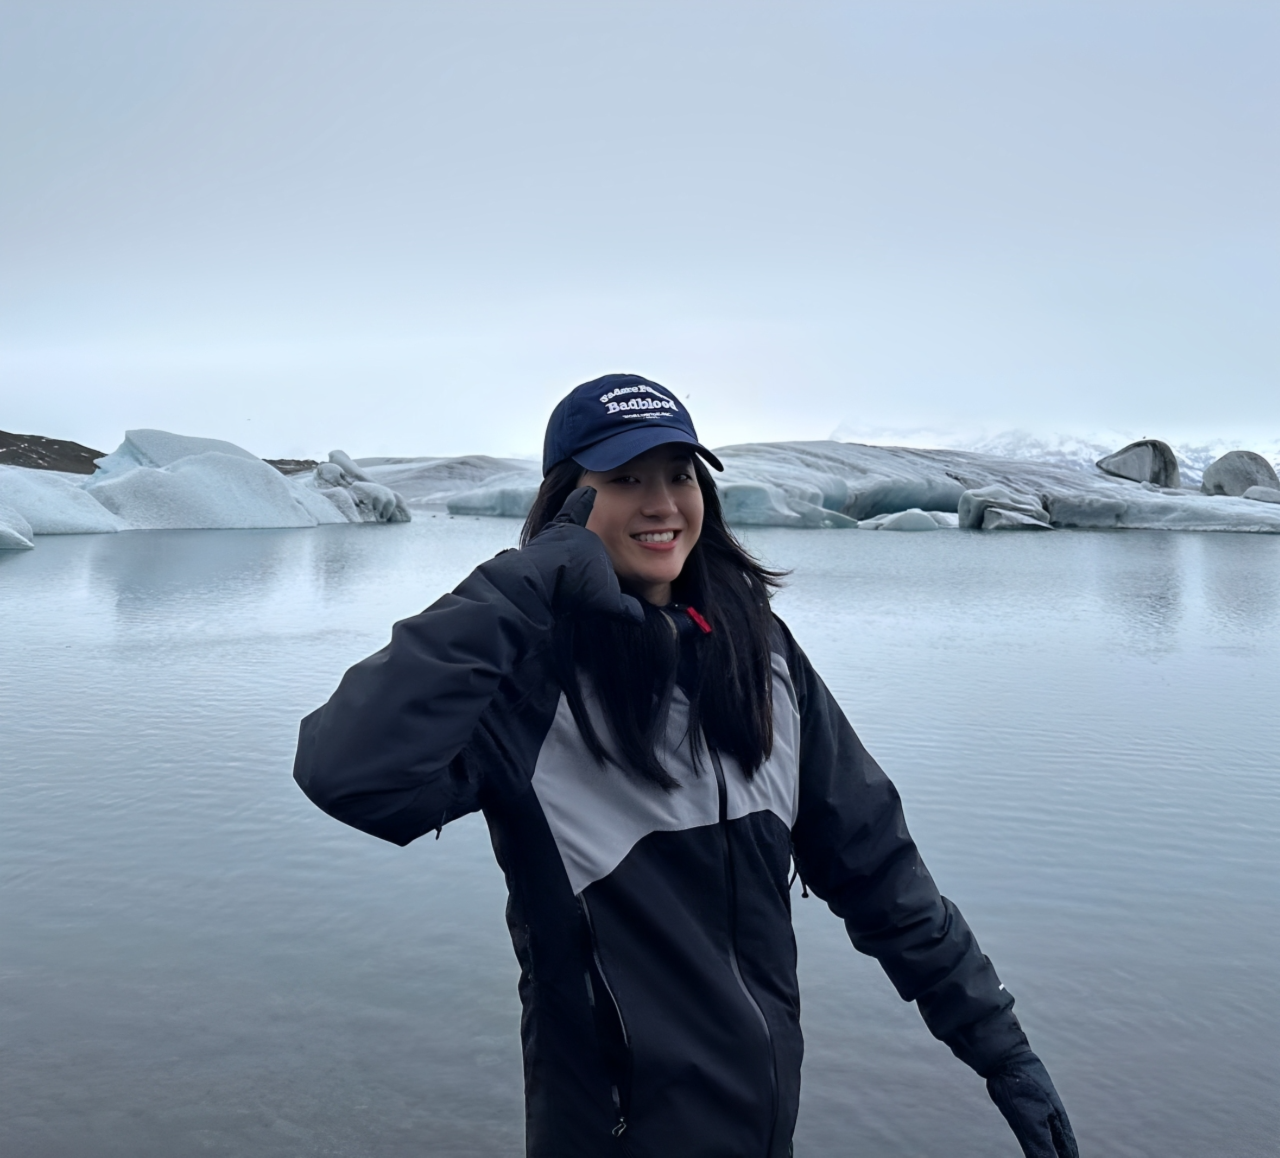
About
Hello 👋 I'm a postdoc at the
Smart Systems Institute, National University of Singapore (NUS),
advised by Prof. Harold Soh.
In 2025, I obtained my PhD from the Faculty of Computing,
Harbin Institute of Technology (HIT), advised
by Prof. Yi Guan and
Prof. Jingchi Jiang.
From 2023 to 2024, I was a visiting PhD student at the University of Edinburgh (UoE), advised by Prof. Stefano V. Albrecht.
Research Highlights
I am interested in creating robots and agents that are capable by training, steerable by inference, and improved by experience. Today, a robot’s capabilities are no longer fixed at training time: they can be steered at inference time (diffusion-model guidance, CAR), generalised to new environments (skill learning, SaMI), equipped with action-relevant memory for long-horizon tasks (VLA memory, D&R), and further improved through interaction (fast online adaptation, ARLPE).
If you’d like to chat about any of this, feel free to email me!
Outreach
For junior PhD/Master/undergraduate students and potential collaborators: I dedicate 30 minutes every two weeks to offer mentorship/advising/help. Topics include but are not limited to AI/robotics research, graduate school application, career development, life, etc. If you would like to chat with me, please fill this form to schedule.
Work Experience
|
Postdoctoral Fellow @ National University of Singapore (NUS) - (2025-present)
Postdoctoral Fellow at the Smart Systems Institute, supervised by Prof. Harold Soh. Research on Embodied AI safety and inference-time alignment for diffusion models.
|
|
Research Intern @ Beijing Institute for General Artificial Intelligence (BIGAI) - (2025)
Research on learning robot manipulation from offline expert datasets (human demonstrations and cross-embodiment data).
|
Education

|
University of Edinburgh - (2023-2024)
Project: Skill-aware Mutual Information Optimisation for Generalisation in Reinforcement Learning
Visiting student in the Autonomous Agents Research Group, supervised by Prof. Stefano V. Albrecht; funded by the World's Top Universities Strategic Cooperation Fellowship (in Chinese, “世界顶尖大学战略合作计划”).
|

|
Harbin Institute of Technology - (2019-2025)
Thesis: Causal Reinforcement Learning Generalisation for Healthcare Agents
Completed my PhD at the Faculty of Computing, HIT; defended my viva in March 2025.
GPA: 92.53/100
|
|
Harbin Engineering University - (2015-2019)
B.Eng. in Internet of Things Engineering, College of Computer Science and Technology; awarded Outstanding Graduate and Outstanding Graduation Thesis (2019).
GPA: 88.95/100.
|